Last Updated on 23/03/2026 by Bonnen Battery
What Is an Autonomous Mobile Robot (AMR)? Power System Explained
An Autonomous Mobile Robot (AMR) is a self-driving robot that navigates and performs tasks without fixed guides, and its power system (battery, BMS, charger, etc.) is absolutely critical to performance and safety. In this article, we break down AMRs – how they work, why their battery choice (especially 400V–700V systems) matters, and what to consider for voltage, capacity, BMS, and system integration. You’ll walk away knowing how to pick the right AMR power setup.
Quick definition: What is an AMR?
An Autonomous Mobile Robot (AMR) is like a smart little self-driving delivery truck or forklift. Unlike a traditional Automated Guided Vehicle (AGV) that follows fixed wires or tape, an AMR uses onboard sensors (cameras, lasers, etc.) and software to navigate freely around a warehouse, factory, or construction site. In other words, AMRs can adapt to obstacles and find new paths on the fly, making them much more flexible.
AMRs are popping up everywhere – from warehouses and distribution centers (moving parcels or stock around) to factory floors, construction sites, and even mining operations. Wherever you need goods transported automatically but the environment can change, an AMR is a great fit. These varied applications demand a robust power source, because your robot may need to run all day, carry heavy loads, or climb ramps, and we need to make sure the battery system can handle it.
AMR power architecture – core components
An AMR’s power system ⇱ is more than just a battery. It’s a whole energy architecture that includes:
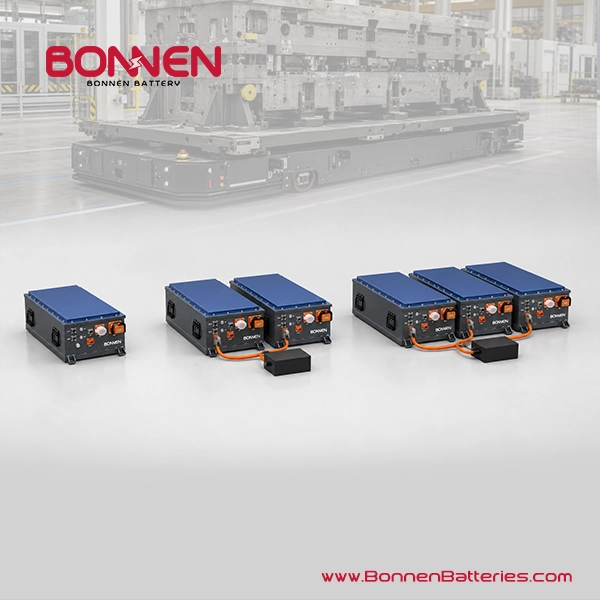
• Battery Pack (cells/modules): The big rechargeable battery itself. For industrial AMRs we often use high-voltage lithium packs ⇱ (400V, 500V, up to 700V) with high energy density. These packs may be built from LiFePO4 ⇱ or other Li-ion cells, giving high capacity and long life without too much weight.
• Battery Management System (BMS): Think of this as the battery’s “brain.” The BMS constantly monitors each cell’s voltage, temperature, state-of-charge (SoC) ⇱, and more. It balances the cells, prevents overcharging/overheating, and communicates with the robot’s controller. A good BMS maximizes safe capacity and protects both the battery and humans from faults.
• DC Bus / High-Voltage Distribution: Inside the robot, high-voltage DC power is distributed via heavy busbars or cables to the motors and electronics. This must be robust and well-insulated to handle the high currents safely. For example, at 400V the current is 4x lower than at 100V for the same power, meaning thinner cables and less heat (we’ll explain why voltage matters next).
• Inverter/Motor Drives: The battery’s DC power usually goes through inverters to drive the electric motors (which often need AC or three-phase power). The inverter converts high-voltage DC to the motor’s required form. Many AMRs use motors similar to EV motors or industrial servo drives, so the power system often resembles a small electric vehicle drivetrain.
• On-board Charger (OBC): This is an internal power module that takes AC from the wall (like 220VAC) and charges the high-voltage battery. Some AMRs have an OBC to plug into standard chargers, while others use off-board charging stations (we’ll cover charging options later). The OBC must be compatible with the battery voltage (e.g. a 400V OBC for a 400V pack).
• Thermal Management: Both the battery and power electronics (inverters, motors, charger) generate heat. AMRs usually have cooling systems — liquid cooling or fans — and heat sensors. Proper cooling is essential so that the battery and components stay in optimal temperature ranges (roughly 15–45°C for LiFePO4, for example). This extends battery life and keeps performance stable.
Each part above is vital. The battery provides energy, the BMS protects it, the distribution system moves the power, and the drives and charger make use of it efficiently. If any piece fails or is mismatched (e.g. a battery too weak for the motors), the robot can’t do its job well.
Why voltage matters – low-voltage vs high-voltage systems
One of the biggest decisions is system voltage. Many small robots run on 24–96V systems (like a big UPS battery pack). But industrial AMRs are increasingly using high-voltage platforms (400V–700V). Why?
• Lower current = less heat: Power (in watts) = Voltage × Current. To deliver the same power, a 400V system needs about 1/4 the current of a 100V system. Lower current means smaller wires, less resistive loss (I²R heat), and lighter cabling. It also means less stress on connectors and switches.
• Efficiency gains: High-voltage DC systems are more efficient over longer distances and times. For a robot running 8+ hours, the energy lost in the power train is reduced if the voltage is higher.
• Compatibility with motors and drives: Many heavy-duty motors and inverters (borrowed from automotive or industrial designs) operate at hundreds of volts. If your robot’s motors need 400–600V input, you must match that with the battery.
• Stability under load: High-voltage batteries tend to maintain voltage more steadily under heavy load. This can be important if the robot needs sudden bursts of power (like lifting a load quickly or climbing a slope).
When should you choose high-voltage (400V+)? In general:
• Medium/heavy robots: If your AMR’s rated power is in the tens of kW, a high-voltage pack (400V–600V) is common.
• Continuous operation: Robots that run constantly (like all shifts) benefit from efficiency and fast recharge of high-voltage systems.
• Heavy payloads or steep ramps: Extra power draw favors higher voltage to manage currents.
Rule of thumb: If your continuous power need exceeds, say, 10–20 kW, consider a 400V+ system. For example, a 20 kW motor at 200V draws 100A, but at 400V it only draws 50A. Lower current is usually a big win.
On the other hand, lower-voltage systems (48V, 96V) still make sense for small, simple robots or where safety rules restrict voltage. But for industrial AMRs with heavy-duty requirements, high-voltage LiFePO4 batteries (like Bonnen’s 400V–700V packs) are becoming the standard.
Capacity & runtime – how to estimate battery size
Another key is battery capacity (in kWh) – basically how much energy it stores.
A simple way to calculate needed capacity is:
Power (kW) × operating time (h) = Energy (kWh)
For example, if your AMR draws 5 kW on average and must run 8 hours, you’d need 5 kW × 8 h = 40 kWh of usable energy.
A table of rough examples:
| Robot Type | Typical Power (kW) | Hours per Shift | Energy Needed (kWh) | Example Voltage | Comments |
| Small indoor picker (light) | 2 – 5 | 8 – 10 | 16 – 50 | 48V – 96V | compact, low weight robots |
| Medium warehouse AMR | 10 – 20 | 8 | 80 – 160 | 400V | higher speed/shelf handling |
| Heavy forklift/contruction | 20 – 40 | 8 | 160 – 320 | 600V – 700V | heavy lifts, long shifts |
Peak power and C-rate: You must also consider peaks. A robot might occasionally draw 2–3× its average power for short bursts (lifting a load, sudden acceleration). This is called the C-rate of the battery. A battery spec sheet will say how many amps it can safely deliver. Usually you want some headroom: design for 20–30% more capacity than the absolute minimum so you aren’t running batteries to the brink all the time.
In short, calculate your mission profile (power × hours), pick a voltage, then size up the Ah rating to get that kWh. Always allow extra margin to preserve battery life and handle peaks.
BMS and safety requirements
The Battery Management System (BMS) ⇱ is a must-have. A good BMS does:
• Cell monitoring & balancing: Checks each cell’s voltage (and often temperature) hundreds of times per second. Keeps all cells at the same state-of-charge to avoid any cell overcharging or over-discharging.
• Overcharge/overdischarge protection: Prevents cells from going outside safe voltage. Shuts down or sheds load if something goes wrong.
• Temperature monitoring: Measures pack and cell temps to avoid overheating. If things get hot, it can throttle power or trigger cooling.
• Isolation monitoring: High-voltage systems need insulation monitoring – the BMS checks that no short develops between the pack and the robot chassis.
• Communication: Modern BMS units report status via CAN bus or RS485 to the robot controller. They provide SoC (state-of-charge), SoH (state-of-health), voltages, etc., so the robot can make smart decisions (like returning to base when low).
Because AMRs can be around people, safety is paramount. High-voltage designs should include emergency disconnects and be thoroughly tested. The battery pack itself should meet standards like UN38.3 (for safe transport of Li batteries), IEC 62619, UL 2580 (for EV batteries), and CE marking. Bonnen Battery packs are compliance with UN38.3, UL, CE, etc., so you know they passed drop, short, overcharge, and thermal tests.
In high-voltage packs (400V+), extra precautions are needed: robust insulation, an emergency quick-disconnect switch, and solid enclosure (often IP-rated to keep dust/water out). For example, an IP66 enclosure (dust-tight and powerful water jets protected) is common for warehouse/industrial AMRs. Fire-suppressant designs or vents to safely release pressure can also be used.
Mechanical & environmental considerations
Robots move around, so the battery must handle real-world conditions:
• Enclosure: Rugged metal or reinforced plastic case. Should be vibration- and shock-resistant since robots can bump into things or drive on uneven floors. Many AMR batteries are rated IP65/IP66 (dust tight, water jet resistant) to survive forklift blows, dust, or even rain if used outdoors.
• Thermal management: In a tight robot chassis, heat can build up. The battery pack should allow airflow or have liquid cooling plates. The enclosure design should channel heat away from the cells and BMS electronics.
• Mounting and space: Space in an AMR is premium. Batteries might be flat to sit in the base, or modular so you can add cells. Batteries should be easy to replace or swap (quick-connect plugs, hand-release latches).
• Maintenance: Design the pack so that failing cells or modules can be replaced easily. Include a way to check cell health (via the BMS interface) and accessible connectors for diagnostics. A regular maintenance plan (e.g. periodic capacity checks) keeps robots running smoothly.
In tough environments like construction or mining robots, you might need even heavier duty: anti-corrosion coatings, extreme temp versions (for hot outdoors or cold warehouses), or ruggedized connectors. Bonnen Battery offers custom design, so they can tailor the mechanical build to your scenario.
Charging strategy & operational workflow
How you recharge your AMR batteries matters as much as the battery itself:
• On-Board Charger (OBC) vs External Charger: Some robots charge on the dock via an onboard charger (plugging into a standard AC outlet). Others use external fast-charger boxes (like EV chargers). OBCs add weight and cost, but give flexibility. External chargers can be bigger and faster.
• Charging speed: Fast charging (high amps) gets robots back quickly but stresses the battery more (heat, cycle wear). Slow charging (overnight) is gentler but needs more downtime. Many operations use a mix: light-charge in breaks, full-charge overnight.
• Shift-based planning: In a multi-shift setup, you might use a battery swap system – where a charged pack is swapped into the robot in seconds. If continuous operation is needed, having two battery packs per robot (one charging while one runs) eliminates downtime.
• Infrastructure: Charging stations should have safety interlocks, ground fault protection, and proper cable management. For high-voltage packs, the chargers must match the pack voltage (e.g. a 400V charger for a 400V pack). Bonnen Battery can supply both the battery and compatible chargers as a full solution.
Typical applications & case examples
Here are a few scenarios to illustrate power needs:
• Warehouse picker AMR: A medium-speed robot moving cartons indoors, say ~10 kW motors, 8h shifts. It might use a 400V, 50 kWh LiFePO4 pack. (Enough to run all day with some margin, quick charge in lunch break.) The battery should be IP66 and support 4,000+ cycles.
• Construction/off-road robot: E.g., an autonomous vehicle at a jobsite lifting 1000 kg. It may need 20–40 kW peak, so a 600V, 100 kWh pack helps keep currents reasonable and runtime long. This pack needs rugged enclosure, maybe even higher IP (like IP67), plus liquid cooling.
• Mining AGV: A heavy-duty haul truck or platform in a mine could have a 700V battery (similar to some EV buses) of 200 kWh or more for long continuous operation. It would have robust battery heating/cooling, advanced BMS, and compliance with mining safety standards.
Below is a simplified table summarizing such example applications:
| Application | Voltage | Capacity | Key Needs |
| Warehouse AMR (light duty) | 400–500V | 20–50 kWh | Long runtime, fast charge, IP66, 4,000+ cycles |
| Construction/off-road robot | 600–700V | 50–120 kWh | High peak power, rugged design, thermal control |
| Mining AGV | 600V | 150+ kWh | Long shifts, heavy loads, full waterproofing, EMC safety |
(Table: Example AMR battery specifications for different use cases. Actual requirements depend on the robot design.)
Common mistakes & design pitfalls
Engineers often stumble on these traps:
• Mismatched voltage: Using a battery with the wrong voltage for the motors/inverter. For example, a 600V battery on a 400V motor drive can fry it. Always align pack voltage to the drive chain.
• Ignoring thermal limits: High current draw without proper cooling can overheat cells or damage the BMS. Always test under worst-case loads.
• Underestimating peaks: Designing for only average load means the pack could sag or shut down during bursts. Size for peak (consider current rating in “C” terms).
• Weak BMS: A cheap BMS might save cost but risks safety. Ensure the BMS has all needed protections and a reliable watchdog.
• Poor enclosure: Skipping IP-rated enclosure for a dust-prone environment leads to failures. Use IP65/66 at least for industrial robots.
• Battery aging: Not accounting for capacity fade. Allow extra capacity (20–30%) beyond day-one spec, or plan to swap/refresh packs after a few years.
• No charging plan: Thinking “we’ll charge it overnight” without backup means single-shift operation. Plan your charging docks or swaps if continuous use is needed.
Avoiding these pitfalls leads to a reliable robot fleet that doesn’t quit on you in the middle of a shift.
Recommended next steps
At this point, you should have a clear picture: An AMR’s power system is the backbone of the whole robot. Getting the voltage, capacity, BMS, and integration right ensures your robot is fast, safe, and always ready to go.
If you’re designing or buying an AMR, consider talking to battery experts. Bonnen Battery offers customizable AMR lithium battery packs (400–700V) specifically built for these requirements. We can tailor voltage, capacity, and shape to fit your platform, and we stand by our products with global support.
👉 Check out our full AMR battery solutions on the Bonnen Battery website: Autonomous Mobile Robot Lithium Battery 400V–700V.
FAQs
Q1: What is the ideal voltage for an AMR battery?
There’s no one-size-fits-all. Small indoor AMRs often use 48V–96V systems, but industrial robots usually need 400V or more. Higher voltage means less current and higher efficiency, so if your motors/inverters support it, 400–700V is common for heavy-duty AMRs.
Q2: How long will an AMR battery last?
It depends on capacity and usage. A 50 kWh pack at moderate loads might run a day (8–10 hours). Bonnen’s AMR batteries boast 3,000–4,000 charge cycles – that’s years of use. Always design for a bit more capacity than your average need to account for aging.
Q3: Why use LiFePO4 chemistry?
LiFePO4 (a type of Li-ion) is safer and longer-lasting than lead-acid or other chemistries. It’s stable (less chance of thermal runaway) and can deliver 4000+ cycles. It also charges faster and has higher energy density (lighter weight).
Q4: Can Bonnen’s batteries work outdoors or in harsh weather?
Yes. Many Bonnen AMR batteries have IP66 (or higher) rating, meaning they’re dust-tight and can handle water jets. For really tough conditions (rain, mud), you can request even higher sealing (IP67+), plus special coatings on electronics.
Q5: How does a BMS improve AMR safety?
The BMS constantly checks each cell and shuts things down if voltages or temperatures go out of range. It prevents overcharging, short circuits, and overheating, which are major safety risks. Without a robust BMS, a battery could fail unexpectedly.
Q6: Is it better to charge the battery or swap it?
Both strategies work. Charging (using on-board or external chargers) is simple and common. Swapping packs can cut downtime – you just plug in a fresh pack and recharge the old one separately. However, swapping needs spare batteries and takes space. Consider your operation hours and costs.
Q7: What if my robot uses different voltages?
You can integrate a DC/DC converter. For example, a 400V pack with a converter to 48V for some electronics. Or use multiple batteries (e.g., 48V for low-power subsystems, 400V for drive) and manage them with controllers. Bonnen can tailor multi-voltage solutions if needed.
Q8: How do I know if a battery is the right size?
List the robot’s power profile: motors, sensors, lights, etc., and calculate average and peak draw. Then use Power (kW) × Hours = Energy (kWh) plus a safety margin. Bonnen’s engineers can help model it – just contact us with your specs.
Q9: What if my robot is an AGV, not an AMR?
The power needs are similar. Bonnen’s high-voltage batteries work for AGVs too. The key difference is navigation style, not power. AGVs can also use 400–700V packs if they need high power or long runtime.
Q10: Does Bonnen Battery provide chargers too?
Yes, we can supply matched chargers and OBCs for our packs. Our focus is turn-key solutions, so we ensure the charger, pack, and robot all integrate seamlessly.
Q11: What certifications should I look for?
Ensure the pack meets international standards: UN38.3 (transport), CE/UL (electrical safety), IEC 62619 (battery safety). Bonnen batteries carry these certificates, so they’re ready for export and commercial use.
Q12: How can I contact Bonnen Battery for an AMR battery quote?
Reach out on our website: Contact Us at Bonnen Battery. Tell us your robot specs (voltage, capacity, size constraints) and we’ll propose a custom LiFePO4 solution that gets your robot moving.
Contact Bonnen Battery↓ now and let us help you power your adventures with the best in lithium battery technologies.
© [Bonnen Battery] and [www.bonnenbatteries.com]. Unauthorized use and/or duplication of this material without express and written permission from this site’s author and/or owner is strictly prohibited. Excerpts and links may be used, provided that full and clear credit is given to [Bonnen Battery] and [www.bonnenbatteries.com] with appropriate and specific direction to the original content.
Application Category
Get In Touch Bonnen Battery
Xiangfeng Science Industrial Park, Changsha City, Hunan Province, China
Email: [email protected]