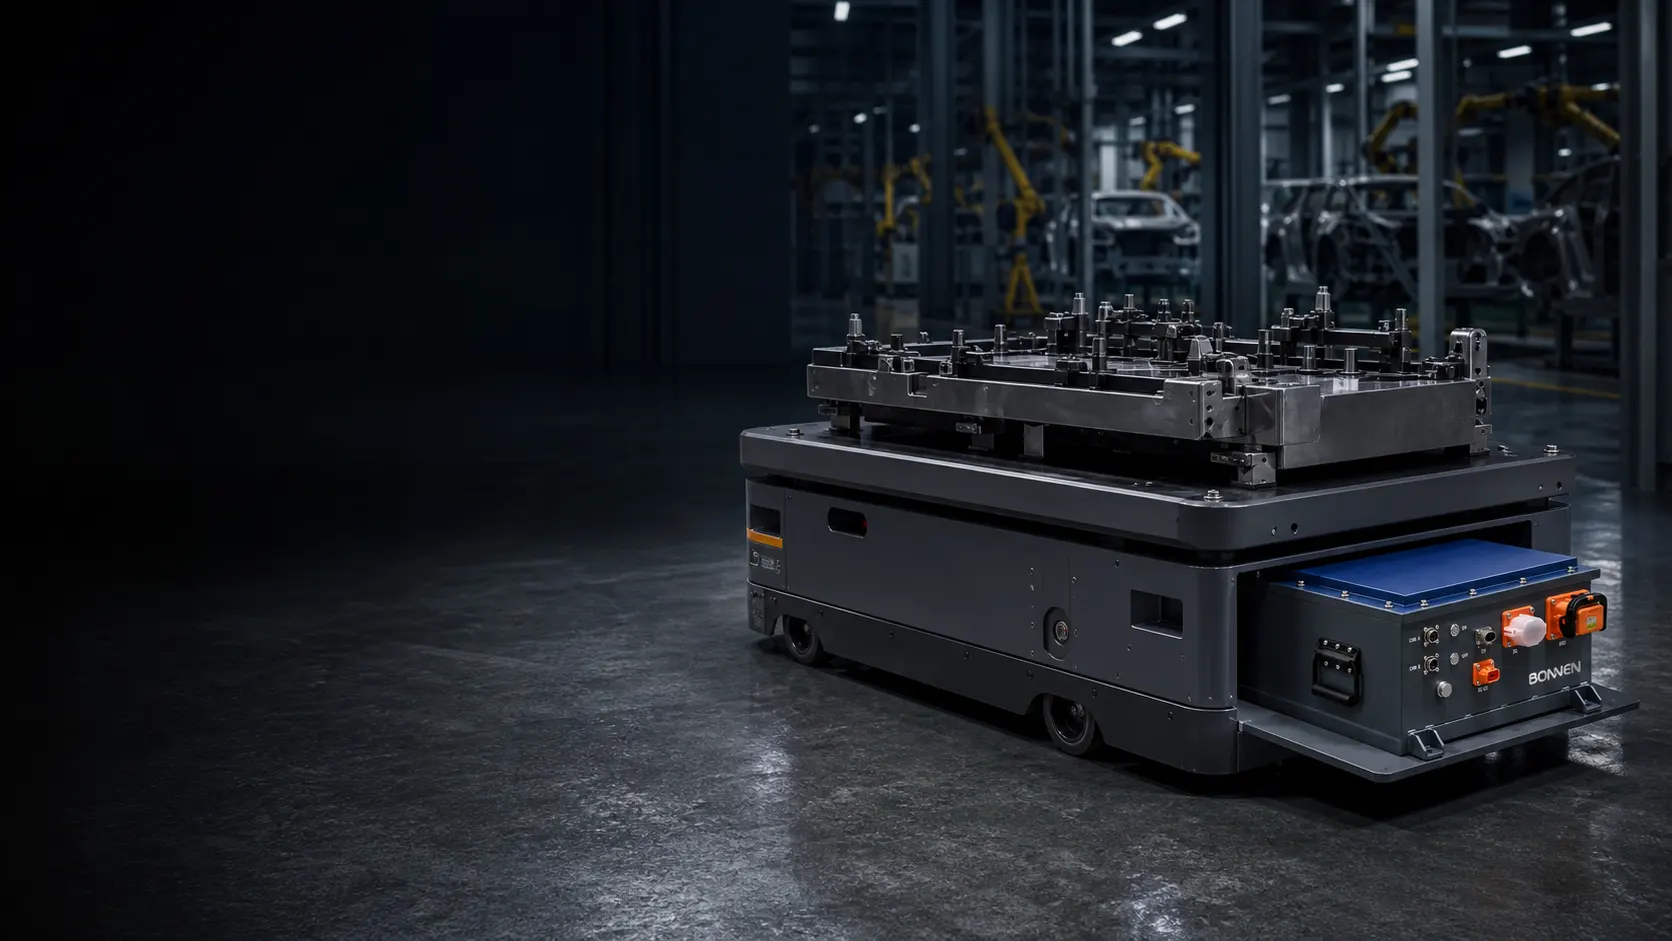
Complete low-profile heavy-duty AMR carrying automotive tooling with one integrated modular battery

48V / 96V / 144V Modular LiFePO4 Platform

Heavy-Duty AMR & AGV Battery Systems

A scalable 304Ah battery platform for heavy-duty autonomous mobile robots, AGVs, and industrial transporters. Configure one, two, or three low-profile modules into coordinated 48V, 96V, or 144V traction battery systems.

14.59–43.77kWhConfigured nominal energy
300A continuousModule-level capability
600A peakModule capability; duration to confirm
IP67 aluminumConfirmed module enclosure
Master-slave BMSCoordinated system architecture

Common platform

One Battery Module. Three System Voltages.

A common 48V 304Ah LiFePO4 module can be engineered into coordinated 48V, 96V, or 144V traction battery systems. This modular AMR battery system supports different vehicle power classes without forcing a complete battery redesign for every platform.

One, two, and three identical battery modules arranged as coordinated traction system configurations
48V 304Ah1 Module 14.59kWh
96V 304Ah2 Modules 29.18kWh
144V 304Ah3 Modules 43.77kWh

Compare configurations

Select the System Voltage for Your Vehicle Architecture

All three configurations retain 304Ah nominal capacity. Voltage, energy, calculated nominal power, and base-module mass scale with module count.

48V 304Ah System

Medium / Heavy-Duty AMRs

Module count
1 module
Nominal voltage
48V
Nominal capacity
304Ah
Nominal energy
14.59kWh
Operating range
37.5–54.75V
Nominal continuous power at 300A
14.4kW
Base-module mass
Approx. 105kg
System approach
Compact single-module platform

Base-module mass only. HV control components, cabling, connectors, and mounting hardware are not included. Calculated power is not an unconditional certified vehicle output; final system rating depends on the selected BMS limits, HV components, cabling, connectors, thermal design, and project validation.

96V 304Ah System

Heavy-Duty AMRs and AGVs

Module count
2 modules in series
Nominal voltage
96V
Nominal capacity
304Ah
Nominal energy
29.18kWh
Operating range
75–109.5V
Nominal continuous power at 300A
28.8kW
Base-module mass
Approx. 210kg
System approach
Coordinated dual-module system

Base-module mass only. HV control components, cabling, connectors, and mounting hardware are not included. Calculated power is not an unconditional certified vehicle output; final system rating depends on the selected BMS limits, HV components, cabling, connectors, thermal design, and project validation.

144V 304Ah System

High-Power Heavy-Duty AMRs, AGVs, and Autonomous Transporters

Module count
3 modules in series
Nominal voltage
144V
Nominal capacity
304Ah
Nominal energy
43.77kWh
Operating range
112.5–164.25V
Nominal continuous power at 300A
43.2kW
Base-module mass
Approx. 315kg
System approach
Coordinated high-power platform

Base-module mass only. HV control components, cabling, connectors, and mounting hardware are not included. Calculated power is not an unconditional certified vehicle output; final system rating depends on the selected BMS limits, HV components, cabling, connectors, thermal design, and project validation.

Coordinated control

Engineered as a Complete Traction Battery System

The 96V and 144V configurations are managed systems, not unrelated smart batteries casually connected in series. A master-slave BMS coordinates module monitoring, system switching, protection, communication, and fault handling.

Switching & pre-charge

Main positive and negative contactors and a pre-charge circuit can be configured around the traction controller.

Protection & service

HV fuse, current sensing, and manual service disconnect are selected to suit the system requirements.

Safety monitoring

Insulation monitoring and HV interlock can be included where required by the final vehicle design.

Vehicle communication

The communication interface and message set are developed around the vehicle controller and charging architecture.

Final component ratings and communication interfaces are selected according to the vehicle voltage window, traction controller, charging system, duty cycle, and safety requirements.

Packaging flexibility

Designed Around the AMR Chassis, Not a Fixed Battery Box

The 580 × 410 × 260mm base module can support central, side-by-side, or distributed layouts. The final arrangement is engineered around chassis height, wheelbase, axle loading, center of gravity, and service access.

Three reference battery modules arranged with service clearance inside a low-profile AMR chassis
01

Low-profile packaging

Use the compact building block to work within demanding chassis-height targets.

02

Distributed installation

Evaluate central or distributed placement around wheel, motor, and structural zones.

03

Vehicle balance

Coordinate battery position with wheelbase, axle loading, and center-of-gravity objectives.

04

Common module strategy

Use one base module across multiple robot platforms where requirements allow.

05

Service planning

Preserve connector access, lifting space, and module removal routes in the chassis.

06

Voltage scaling

Scale system voltage with traction-power requirements through coordinated engineering.

Confirmed base module

The 48V 304Ah Building Block

A compact LiFePO4 module combines high current capability with an IP67 aluminum enclosure for integration into heavy-duty industrial mobile robots.

14.59kWhNominal energy
300AContinuous discharge
600APeak discharge; duration to confirm
150AContinuous charge
Chemistry
LiFePO4
Cell configuration
1P15S
Nominal voltage / capacity
48V / 304Ah
Operating voltage range
37.5–54.75V
Enclosure / protection
Aluminum / IP67
Module dimensions
580 × 410 × 260mm
Approximate module weight
Approx. 105kg

Industrial applications

Built for Heavy Autonomous Transport

This heavy-duty AGV battery platform is intended for industrial mobile robots and autonomous transporters that move large components—not lightweight shelf or picking robots.

Low-profile autonomous transporter moving a large industrial die in a manufacturing facility
Heavy-duty flatbed AMRs
Automotive chassis transport AGVs
EV battery pack transport AMRs
Die and mold transport AGVs
Steel and metal material transporters
Heavy-duty tugger AGVs
Aerospace component transporters
Large custom autonomous forklifts

Designed for multi-ton autonomous transport applications. Final battery sizing is based on vehicle mass, payload, traction power, grade, speed, duty cycle, and charging strategy.

Application engineering

Customized Around Your AMR Platform

Mechanical, electrical, charging, and communication details are developed around the vehicle. Optional features are available based on project requirements and engineering confirmation.

System voltage & usable energyAligned with the controller voltage window and duty cycle.
Module quantity & arrangementPackaged around space, balance, and service access.
Continuous & peak powerValidated with BMS, conductors, connectors, and thermal design.
Master-slave BMS integrationCoordinated monitoring and system-level control.
Vehicle communication protocolDefined around the target controller and message requirements.
HV connectors & cablesSelected for current, voltage, routing, and service needs.
Charging interface & strategyEvaluated against charger, schedule, and operating window.
Thermal requirementsDefined from ambient conditions, power, and operating profile.
Mounting & service accessDeveloped with mechanical retention and maintenance routes.
Vehicle controller integrationCoordinated through system interfaces and fault behavior.

Start the sizing process

What We Need to Size Your AMR Battery

A useful proposal begins with the machine, its power demand, the operating profile, and the available installation space.

01

Robot or vehicle application

02

Vehicle mass and payload

03

Motor voltage and power

04

Continuous and peak power

05

Maximum speed and grade

06

Required operating time or shift profile

07

Charging method and available charging time

08

Available battery space

09

Communication requirements

10

Environmental conditions

Don’t have every specification yet? That’s fine. Send us the information currently available, and our battery engineering team will help identify the remaining design inputs.

FAQs About 48V, 96V and 144V Heavy-Duty AMR Battery Systems

You need more than just a single lithium ion battery pack​. You need a veteran manufacturer who has been in the field for 10+ years to save your project time, build your brand and grow your profits. Let Bonnen Battery help you achieve business success.

The right voltage depends on your traction controller, motor power, vehicle weight, payload, duty cycle, and required operating time. A 48V system can suit medium to heavy-duty AMRs with moderate traction power, while 96V is better suited to many heavier industrial AGVs and AMRs. For higher-power autonomous transporters, a 144V architecture can deliver more power without requiring proportionally higher current, but the final voltage should always be matched to the vehicle’s complete electrical architecture.

It can be, depending on the vehicle. The 48V 304Ah configuration provides 14.59kWh of nominal energy and is based on a single low-profile battery module. Whether that is enough depends on the AMR’s total mass, payload, motor power, speed, grade, operating hours, auxiliary loads, and charging opportunities rather than battery capacity alone.

Yes, a 96V 304Ah battery system can be a good fit for heavy-duty AGVs and AMRs that need more traction power and energy than a typical 48V platform. The Bonnen configuration uses two coordinated 48V 304Ah modules to provide 29.18kWh of nominal energy, with the final system engineered around the traction controller, BMS, high-voltage components, charging system, and vehicle duty cycle.

A 144V 304Ah battery is worth considering for high-power heavy-duty AMRs, large AGVs, and autonomous industrial transporters carrying substantial loads. The three-module configuration provides 43.77kWh of nominal energy and allows higher system power at the same current level than the 48V or 96V versions. Final suitability still depends on motor requirements, payload, grade, operating time, and controller voltage limits.

The amp-hour capacity remains 304Ah, but system voltage and total energy increase as additional modules are added in series. The 48V system provides 14.59kWh, the 96V system provides 29.18kWh, and the 144V system provides 43.77kWh. Higher voltage also allows more power to be delivered at the same current, which can be useful for heavier vehicles and higher-power traction systems

For a heavy-duty traction application, we do not recommend treating two independent smart batteries as ordinary batteries and simply connecting them in series. A 96V AMR battery should be engineered as one coordinated system with module monitoring, a master-slave BMS architecture, appropriate contactors, pre-charge circuitry, fusing, current sensing, communication, and system-level fault management.

Yes, but they should be designed as a coordinated 144V traction battery rather than three unrelated standalone batteries. In Bonnen’s architecture, three 48V 304Ah modules can form a 144V 304Ah system, with the modules supervised through a master-slave BMS and supported by appropriately rated high-voltage protection and control components.

This battery platform is intended for larger industrial mobile robots rather than small warehouse shelf robots. Typical applications include heavy-duty flatbed AMRs, automotive chassis transport AGVs, EV battery pack transport AMRs, die and mold transport AGVs, steel and metal material transporters, heavy-duty tugger AGVs, aerospace component transporters, and large custom autonomous forklifts.

Yes, the platform is intended for multi-ton autonomous transport applications, but vehicle weight alone is not enough to select the battery. Payload, acceleration, maximum speed, road grade, wheel and drivetrain efficiency, motor power, operating hours, charging opportunities, and installation space all need to be considered when sizing a battery for a multi-ton AMR.

LiFePO4 is well suited to many industrial AMR and AGV applications because it combines cycle-life potential, thermal stability, high-current capability, and practical durability. Bonnen’s 48V 304Ah base module uses LiFePO4 cells and is designed as a building block for heavy-duty industrial traction battery systems.

The base 48V 304Ah battery module uses an aluminum enclosure rated to IP67. This makes the module suitable for demanding industrial environments where protection against dust and temporary water exposure is important, although the complete vehicle installation, connectors, cables, vents, and external components must also be designed to maintain the required environmental protection level.

The base module measures approximately 580 × 410 × 260mm and weighs about 105kg. A complete 96V or 144V system uses multiple modules, so the finished system weight will also include high-voltage control components, cables, connectors, mounting hardware, and other project-specific equipment.

The 580 × 410 × 260mm module was designed as a relatively low-profile building block for industrial mobile robots. Depending on the chassis, modules can be evaluated for central, side-by-side, or distributed installation while considering ground clearance, wheelbase, axle loading, center of gravity, connector access, and future maintenance.

The 48V 304Ah base module is specified for up to 300A continuous discharge and up to 600A peak discharge, with the permitted peak-current duration subject to engineering confirmation. The final vehicle-level current and power rating also depends on the BMS, contactors, fuse, cables, connectors, thermal conditions, and traction controller.

There is no universal kWh value for a heavy-duty AMR because two robots with the same payload can have very different energy consumption. Battery capacity should be calculated from the vehicle’s real duty cycle, including loaded and unloaded travel, acceleration, speed, gradients, turning, idle time, onboard electronics, operating hours, charging opportunities, and the usable SOC window.

Start with the AMR’s average energy consumption during a representative working cycle rather than dividing battery kWh by motor nameplate power. Traction motors rarely operate continuously at rated power, so the correct calculation should consider loaded travel, unloaded travel, acceleration, stopping, idle periods, auxiliary loads, regenerative braking if available, usable battery energy, and the required reserve at the end of the shift.

Yes. Multi-module configurations are managed through a coordinated master-slave BMS architecture. Slave monitoring units supervise individual battery modules while the master BMS manages system-level functions such as monitoring, protection, switching, communication, and fault handling across the complete traction battery.

Yes, the communication interface and message requirements can be developed around the target AMR controller, charger, and vehicle architecture. When requesting a custom AMR battery, it is helpful to provide your controller documentation, communication protocol, required messages, baud rate, fault-handling requirements, and any available CAN database or interface specification.

Yes. The charging interface and charging strategy should be matched to the system voltage, battery capacity, operating schedule, available charging time, and the AMR’s working pattern. This is especially important for robots using opportunity charging between tasks or short charging windows during multi-shift operation.

Not every heavy-duty AMR requires liquid cooling. Thermal requirements depend on continuous current, peak power, ambient temperature, duty cycle, enclosure location, charging rate, available airflow, and how frequently the vehicle operates under high load. The thermal solution should therefore be selected during system engineering rather than assuming that every AMR battery needs the same cooling method.

Yes. Battery packaging can be developed around available chassis space, wheel position, structural members, motors, ground clearance, axle loading, and service access. Using the common 48V module as a building block also makes it possible to evaluate different central or distributed layouts for 48V, 96V, and 144V vehicle architectures.

The most useful information includes the AMR application, vehicle weight, maximum payload, motor voltage and power, continuous and peak power demand, maximum speed, grade, required operating time, charging method, charging window, available battery space, communication requirements, and environmental conditions. These details allow the battery system to be sized around the actual vehicle rather than selecting a battery only by voltage and Ah.

That is not a problem. You can send the information you already have, such as motor voltage, motor power, payload, approximate operating hours, available installation space, or even just the vehicle concept. Bonnen’s battery engineering team can use the available information to identify what additional data is needed before finalizing the battery configuration.

Yes. Automotive chassis transport AGVs and EV battery pack transport AMRs are among the types of heavy autonomous transport applications this modular platform is intended to support. The final battery is engineered around the transporter’s payload, traction power, duty cycle, required operating time, charging strategy, chassis space, vehicle communication, and service requirements rather than using a generic off-the-shelf battery.

Engineering proposal

Build the Right Battery System for Your AMR

Share your motor, vehicle, payload, duty-cycle, and installation requirements. Our engineering team will evaluate the appropriate system voltage, energy, power capability, module layout, BMS architecture, and charging approach.

Your project details will be reviewed by our battery engineering team. NDA support is available.